
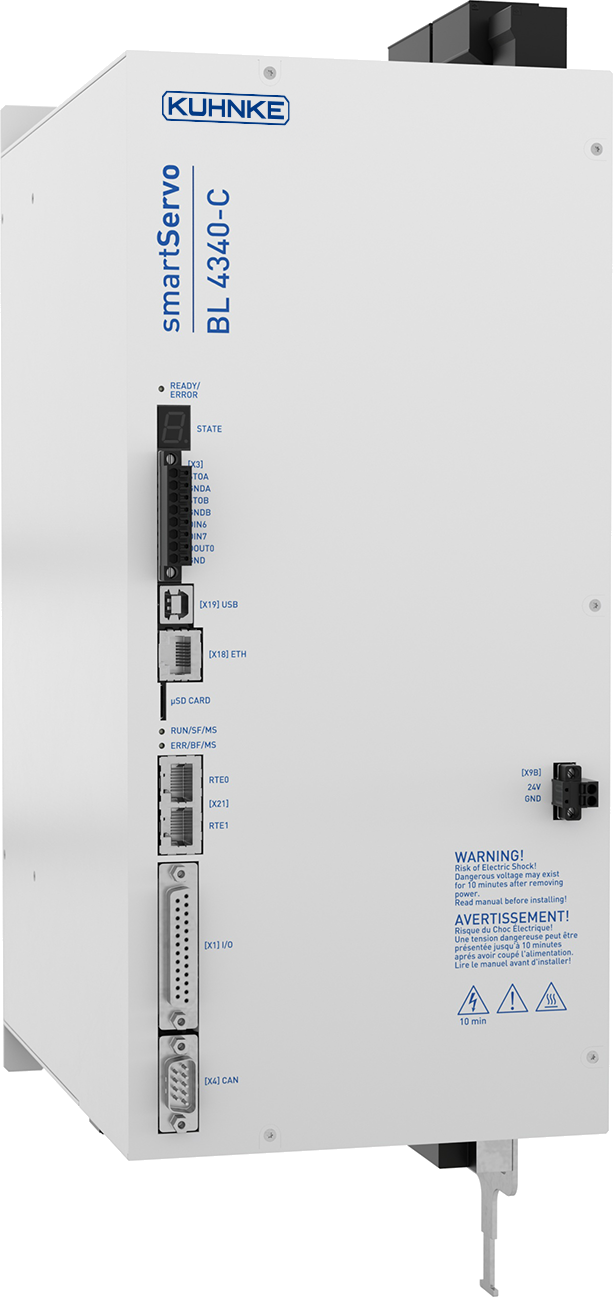
Kuhnke BL4340.C 40 A Servo Drive
Product code: BL4340.C
BL servo drives support a wide range of motor types and common position encoders. By parameterizing the integrated technology functions, they can be adapted to different applications. High-precision evaluation of external signals in the drive enables short cycle times. Technology…
Phone: 0850 885 03 51
Datasheet, user manual and software packages if available.
Technical Specifications
| Brand | Kuhnke |
|---|---|
| Model / Product Code | BL4340.C |
| Series | BL |
| Rated Output Current | 40 A |
| Output Power | 16 kW |
| 2 s Max. Output Power | 40 kW |
| 2 s Max. Output Current | 100 A |
| Supply Voltage | 3 x 230…480 VAC |
| Fieldbus Interfaces | CANopen, Ethernet, EtherCAT, PROFINET |
| Encoder Interfaces | EnDat 2.2, HIPERFACE®, HIPERFACE DSL®, incremental encoder, resolver, FA-CODER |
| Safety Functions | STO, SS1, SOS, SS2, SLS, SSR, SBC, SSM, SDI |
Description
BL servo drives support a wide range of motor types and common position encoders. By parameterizing the integrated technology functions, they can be adapted to different applications. High-precision evaluation of external signals in the drive enables short cycle times.
Technology Functions
Positioning: Whether linear, jerk-limited or torque-limited — motion tasks are carried out with the integrated positioning control.
Path program / Linking: All 256 positioning sets can be chained together, so that complex positioning tasks can be solved without an external control system. Digital inputs allow conditional branching.
Flying saw: By integrating the flying saw function into the drive, high accuracy is achieved in addition to short cycle times.
Electronic gear / Synchronization: Position-synchronous or speed-synchronous motion of different drives with variable gear ratios is quickly parameterized via the software assistant.
Cam disk: Together with the integrated virtual master and synchronization, the electronic cam can be used to coordinate multiple drives.
Linear motors: Special methods for determining the commutation position and the corresponding monitoring functions allow linear motors to be operated without commutation information.
Rotary table: Various rotary axis modes are available for rotary table applications. These can be combined with the cam disk and the electronic gear.
Switching cams: Switching cams linked to the position trigger, rotor position trigger and cam disk can easily be parameterized and assigned to digital outputs.
Safety Functions
STO – Safe Torque Off: Disconnection of the drive’s power supply in accordance with EN 61800-5-2. This function ensures that the drive can no longer generate power.
SS1 – Safe Stop 1: The drive is braked independently to a standstill within a defined time using a defined braking ramp, after which the power supply is safely switched off. SS1 type C is supported.
SOS – Safe Operating Stop: Used when the motor position or axis position must be actively maintained and safely monitored.
SS2 – Safe Stop 2: The drive is braked to a standstill within a defined time using a defined braking ramp. When the defined time elapses, SOS (safe operating stop) is triggered. All three variants described in the standard are supported.
SLS – Safely Limited Speed: Prevents the motor from exceeding the defined speed limit.
SSR – Safe Speed Range: Used when the drive speed must be kept within a defined range.
SBC – Safe Brake Control: Provides a safe output signal to control external motor brakes. This prevents unwanted movement in the torque-free state. An external holding brake with its own power electronics can also be controlled via the safe outputs.
SSM – Safe Speed Monitor: Monitors the drive’s speed within defined limits. If the limits are exceeded or fallen below, a safety-related signal output is triggered.
SDI – Safe Direction: Ensures that the drive can only move in the defined direction.
Communication Interfaces
CANopen, Ethernet, EtherCAT, PROFINET.
Encoder Interfaces
EnDat 2.2, HIPERFACE, HIPERFACE DSL, incremental encoder, resolver, FA-CODER.