
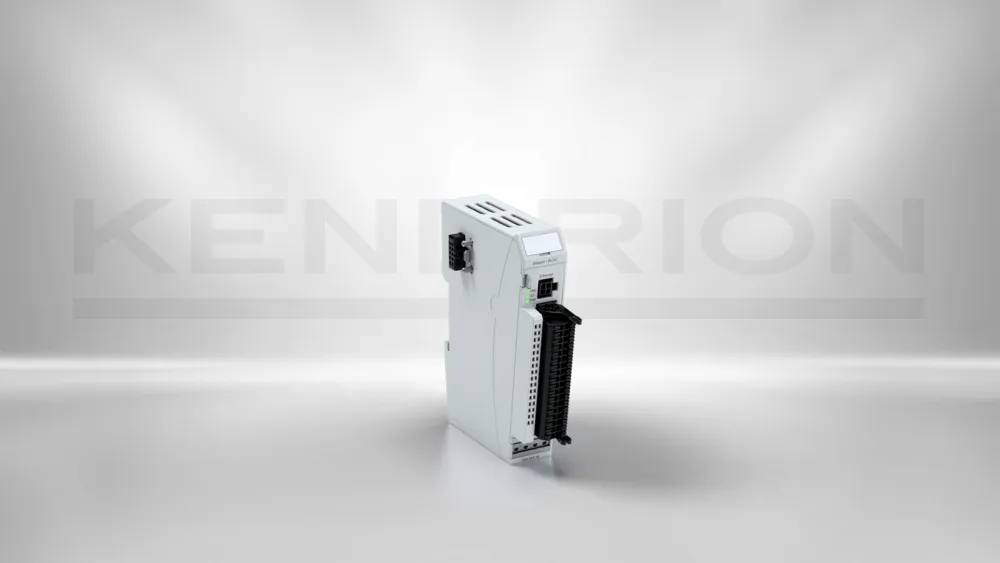
Kuhnke FIO Drive Control Drive Module
Product code: 69445416
This compact drive controller can be used for both stepper motors and brushless DC motors. Field-oriented vector control, encoder feedback and sine-wave commutation together provide high dynamics; in particular, efficient and smooth operation with low running noise is achieved when…
Phone: 0850 885 03 51
Datasheet, user manual and software packages if available.
Technical Specifications
| Brand | Kuhnke |
|---|---|
| Model / Product Code | 69445416 |
| Function | Motion control |
| Mounting | In-panel module |
| Digital I/O (Built-in) | Output: Motor, Brake / Input: Incremental encoder, Hall encoder, 5 DI |
| Built-in Function | Interpolation, positioning, speed operation, torque regulation, reference movement according to DSP402 |
| Interfaces | Motor types: 2-phase step motor or brushless DC motor with/without incremental encoder connection, connection voltage 12 - 72 V DC, motor rated current 5 A, Options: LAN interface |
| Product Status | Active (from stock or to order) |
| Fieldbus Interfaces | EtherCAT |
| Connection Type | Female connector with PUSH-IN spring connection |
| Housing Material | Aluminium frame, plastic housing |
| Dimensions (W x H x D) | 25 x 120 x 90 mm |
| Protection Class | IP20 |
| Supply Voltage | 24 V DC (-15% ... +20%) |
| Operating Temperature | 0 ... +55 °C |
| Certifications | CE, UL |
Description
This compact drive controller can be used for both stepper motors and brushless DC motors. Field-oriented vector control, encoder feedback and sine-wave commutation together provide high dynamics; in particular, efficient and smooth operation with low running noise is achieved when driving stepper motors. Step errors are corrected on the fly and the load-angle error is eliminated within a single full step. Thanks to continuous monitoring of the motor current, the controller delivers only as much power as needed. To reduce the certification effort, the module holds UL certification (cULus) for the US and Canadian markets.
Operating modes: Interpolation (cyclic synchronous position mode) · Referencing (Homing Mode) · Positioning mode (absolute / relative) · Velocity mode, Torque mode